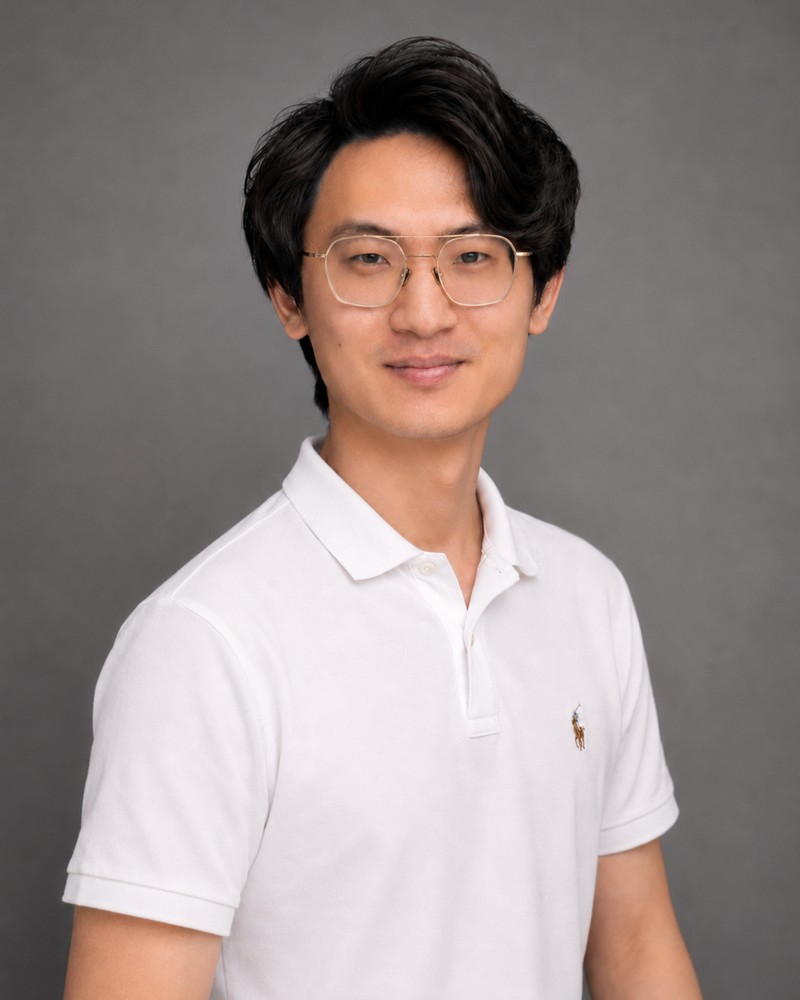
Haocheng Zhao
PhD student at the Learning Systems and Robotics Lab, Technical University of Munich
I study how robots can act safely in cluttered, dynamic and partially known environments, with guarantees that hold in real time on real hardware.
I am advised by Prof. Angela P. Schoellig. My research is on safe human-robot interaction: safety filters built on control barrier functions, the geometric representations that make them reliable and fast, and learning-based model predictive control for agile systems. Before the PhD, I completed my Master's in Mechatronics and Robotics at TUM.
News
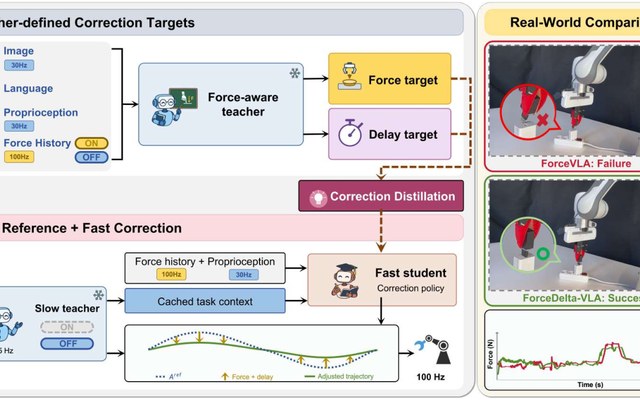
Our work ForceDelta-VLA, on force-conditioned action corrections for contact-rich manipulation, is on arXiv.
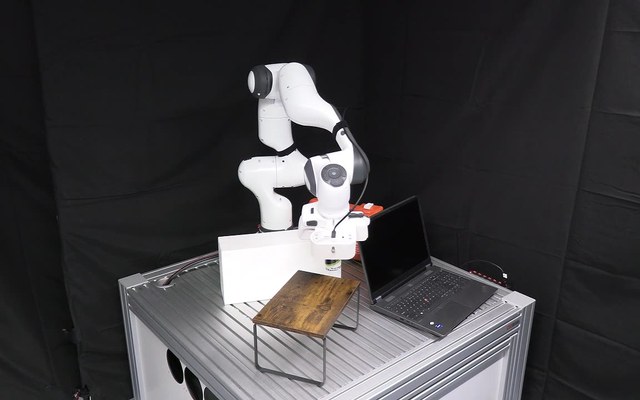
SQ-CBF is accepted to IEEE RA-L. The project page has interactive figures and the real-world videos.
Iterative learning MPC for drone racing is accepted for oral presentation at IROS 2025.
PublicationsGoogle Scholar ↗
-
-
-
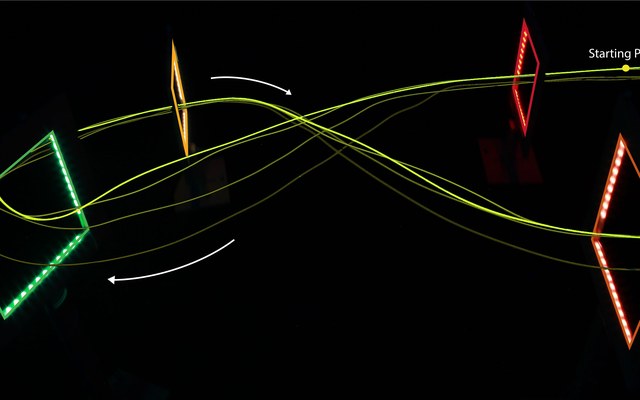
Improving Drone Racing Performance Through Iterative Learning MPC
IROS · 2025 · oral presentation
Contact
I am open to research collaborations, student projects and thesis supervision on safe robot control and manipulation. Write to me with a short note on your interests.
haocheng.zhao@tum.de